SAMEEP
POTE

Robotics Engineering

PORTFOLIO

About Me

Sameep Pote

Summary

Robotics and Software Engineer with expertise in C++, Python, and ROS, specializing in autonomous systems, real-time performance optimization, and AI-driven solutions. Delivered high-impact projects, including a multi-trailer collision avoidance system and scalable trading pipelines, while integrating APIs and building robust, efficient workflows.
Technical Skills

C++ Python Java Java Script ROS Autonomous Systems

Work Experience

Senior Software Engineer

Causify Aug 2023 - Present
  • Integrated the CCXT API using asynchronous programming and REST protocols to efficiently place orders, fetch trades and balances, and cancel orders, optimizing performance for high-frequency trading while ensuring seamless multi-exchange integration.
  • Engineered a zero-latency data extraction pipeline for real-time AI model training and prediction in high-frequency trading, ensuring seamless data flow with minimal latency. Developed multiple Airflow DAGs for QA processes and optimized data migration from RDS to S3 using ELT and ETL pipelines, achieving an 80% cost reduction.
  • Developed and maintained a CI/CD pipeline for seamless deployment of Airflow DAGs in production, incorporating unit tests, version control with GitHub, and automated Slack notifications for failure alerts, ensuring robust data workflows.
  • Implemented a log replay class to enable advanced testing of broker behavior by sequentially replaying experiment logs, simulating interactions with CCXT Exchange using logged data for accurate and reproducible testing scenarios.

Key Achievements

  • Led a team of 5 engineers in developing a new navigation system
  • Reduced system latency by 60% through optimization
  • Published 2 technical papers on autonomous navigation

Autonomous Vehicle Software Engineer

ThorDrive May 2022 - March 2023
  • Developed a ROS package in C++ for trailer path prediction, achieving an accuracy of 98.1%. Converted this package into a collision avoidance system, enabling our ego vehicle to safely maneuver with up to 5 trailers without collisions.
  • Created package for adaptive destination using custom A* algorithm which found path in 15 iterations and 1.464 seconds as compared to 5666 iterations and 14.647 seconds required by tradition Hybrid-A* for the same scenario.
  • Hands-on experience in implementing the gen-1 path-planning pipeline of the company which gave an overall 27% better performance in KPIs. With an addition fail-safe pipeline handled 100 more hardware and software fail case scenarios

Key Achievements

  • Successfully delivered 3 major robotics projects ahead of schedule
  • Improved system reliability by 45% through robust error handling
  • Mentored 2 junior developers in ROS development

Research Scientist

United States Department of Agriculture Feb 2023 - Nov 2023
  • Worked on NSGA-II , Multi-objective PSO and MOCNN for optimization of EPIC model which gave an RMSE of 0.11.
  • Implemented Particle Swarm Optimization Algorithm for model calibration using remote-sensing data.

Featured Projects

Project 1

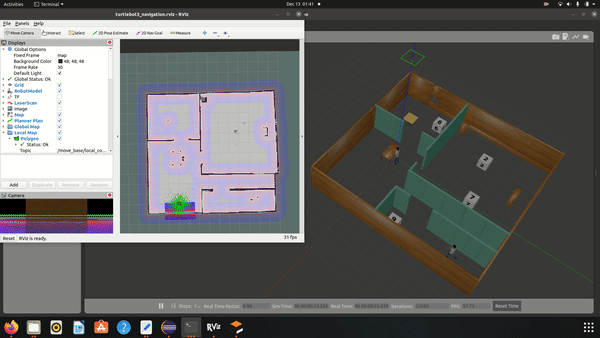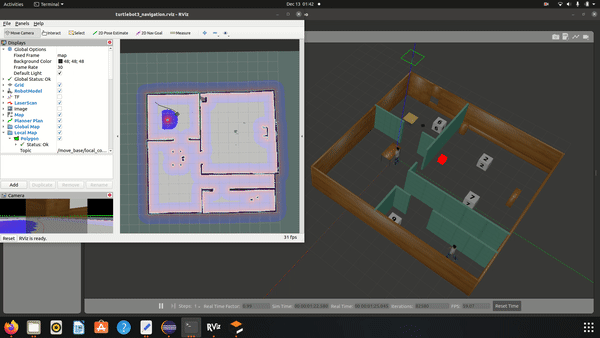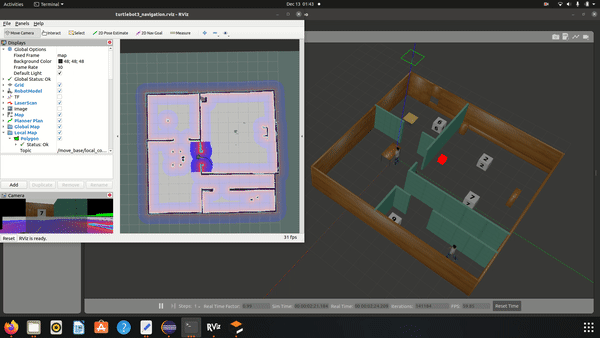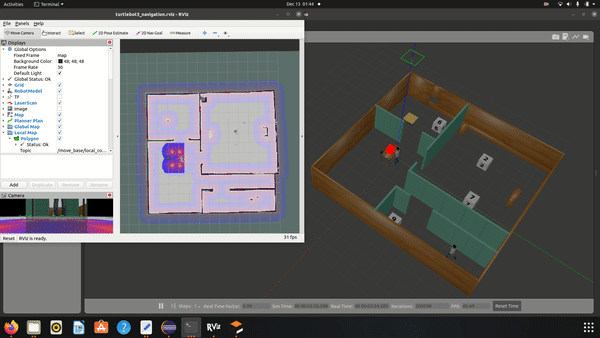
Autonomous Warehouse Collection Robot

Robotics • ROS & C++

Implemented SLAM and AMCL for navigation and localization, alongside various path planning algorithms (Dijkstra, A, RRT, etc.) to enhance efficiency.

Project 2

Electric Autonomous Vehicle

Computer Vision • Python & Pytorch

Implemented YOLOv8 for object detection and tracking, and A* algorithm for path planning.

Project 3

Omnidirectional Robot

Robotics • ROS & C++

Implemented a omni-directional robot with ROS and designed it in real life.

Project 4

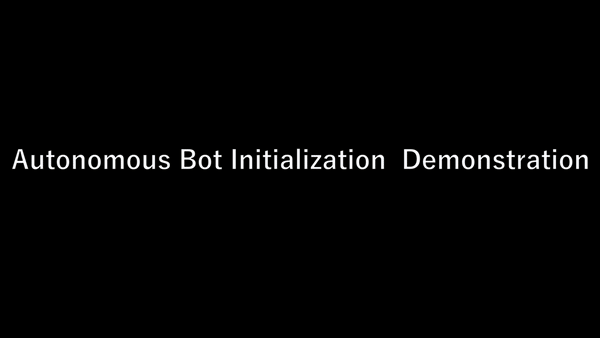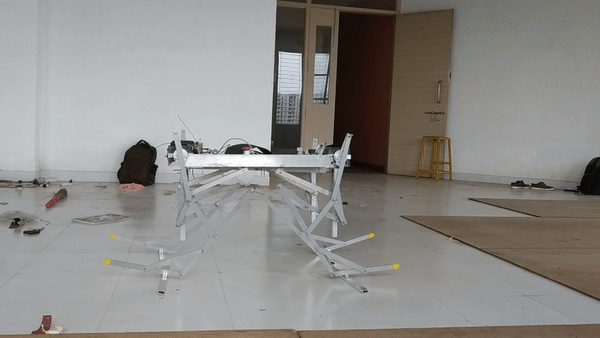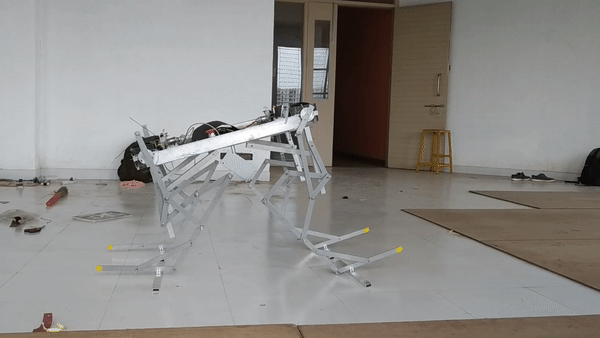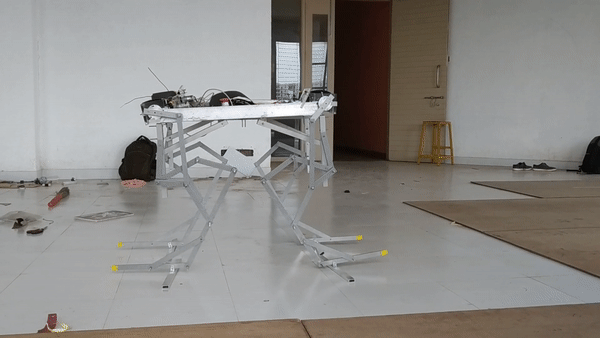
Quadruple Robot

Robotics • ROS & C++

Implemented a quadruple robot with ROS and designed it in real life.

Project 5

Lane Detection

Computer Vision • Python & Pytorch

Implemented Lane Detection using OpenCV.

Get In Touch